Generate wrist torque
The AC motor converts drive current into rotation. Its pinion transfers that rotation to the wrist gearbox, where speed is reduced and torque is delivered to the selected axis.
Welcome to Moore Automation Limited

|
Copy and share this link on social network or send it to your friends
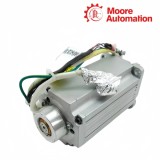
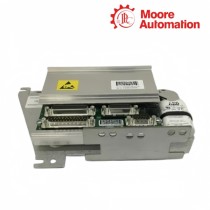
Copy| Product Name | ABB 3HAC047574-002 Type B Rotational AC Motor with Pinion |
| Item NO. | 2930450 |
| Weight | 0.1 kg = 0.2205 lb = 3.5274 oz |
| Category | ABB |
| Brand | ABB |
| Creation Time | 2026-11-06 |
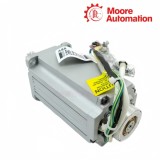
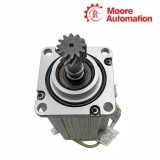
ABB 3HAC047574-002 is a Type B rotational AC motor supplied with its pinion for the ABB IRB 2600 robot. It drives the wrist-axis gear path used by axes 4, 5 or 6 in the applicable manipulator execution, converting controller power into the geared rotation commanded for the selected axis.
Motor power, brake control and resolver feedback remain separate but coordinated paths on ABB 3HAC047574-002. The pinion carries motor torque into the axis gearbox, while the feedback circuit returns shaft position to IRC5 so the controller can compare commanded and measured wrist movement.
Because Type A and Type B motor executions are not interchangeable, ABB 3HAC047574-002 is selected from the robot serial record and installed axis position. Service work preserves connector labels, pinion engagement, cable routing and seals before calibration and a controlled wrist-motion test.
| Technical item | Specification |
|---|---|
| Brand | ABB |
| Model | 3HAC047574-002 |
| Product name | Rotational AC motor with pinion, Type B |
| Country | Sweden / Switzerland |
| Robot family | ABB IRB 2600 |
| Axis application | Wrist axes 4, 5 or 6 by robot execution |
| Mechanical output | Installed pinion to axis gearbox |
| Electrical paths | Motor power, brake and resolver feedback |
| Controller family | ABB IRC5 |
| Execution control | Type B; not interchangeable with Type A |
| Service checks | Connectors, seals, pinion seating and cable support |
| Commissioning | Calibration and controlled wrist-motion test |
ABB 3HAC047574-002 combines torque production, holding-brake action and shaft-position feedback in the wrist drive assigned by the robot configuration.
The AC motor converts drive current into rotation. Its pinion transfers that rotation to the wrist gearbox, where speed is reduced and torque is delivered to the selected axis.
The brake holds the mechanical axis when drive torque is removed. Brake wiring and release timing therefore belong to the same service check as motor power, not to a separate mechanical adjustment.
Resolver feedback reports motor-shaft position to IRC5. The controller uses that value with the robot model to regulate motion and identify a deviation between commanded and actual wrist movement.
Fit ABB 3HAC047574-002 by preserving the Type B drive geometry and every power, brake and feedback connection associated with the original axis.
Move the robot to the documented service position, isolate energy and mechanically support the affected wrist axis before disconnecting the motor or releasing its brake.
Label motor, brake and resolver plugs, protect the gearbox opening, then install the Type B motor so the pinion seats without forcing the housing or trapping seals and cables.
Restore covers and cable supports, update calibration only when required, then release the brake and test low-speed motion while monitoring direction, noise, current and position feedback.
For ABB 3HAC047574-002, use the IRB 2600 serial record and installed-axis spare-parts list before ordering 3HAC047574-002.
For ABB 3HAC047574-002, support the affected axis and isolate drive and brake energy before loosening 3HAC047574-002.
For ABB 3HAC047574-002, label motor power, brake and resolver plugs and return them to the same axis positions.
For ABB 3HAC047574-002, stop the test and check pinion seating, motor alignment, covers and gearbox condition before changing calibration.
For ABB 3HAC047574-002, compare slow commanded motion with displayed axis position and confirm resolver and brake behavior together.
For ABB 3HAC047574-002, test 3HAC047574-002 at controlled speed with the work area clear before restoring automatic operation.
Moore Automation can retain the complete motor identifier, robot serial context, axis position and shipment tracking record so the Type B execution remains visible through packing and delivery.


Moore Automation Sales Team
Copyright © 2004–2026 www.mvme.cn. All rights reserved.
Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.
No related record found