ABB 3HAC046277-001 Serial Measurement Unit with RMU101 SMB
ABB robot measurement systems
ABB 3HAC046277-001Serial Measurement Unit with RMU101 SMB
01
Product Introduction
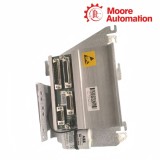
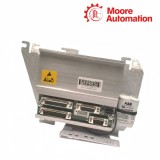
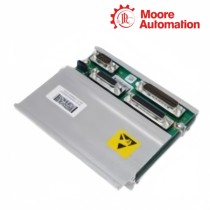
ABB 3HAC046277-001 is a serial measurement unit used in ABB robot measurement systems to collect resolver position data and preserve axis revolution information for the robot controller. Its RMU101 serial measurement board and dedicated battery form the local measurement record that remains available when main controller power is removed.
Resolver leads from the robot axes terminate at ABB 3HAC046277-001, where the measurement board converts the resolver relationships into serial position data for the controller. The unit therefore links mechanical axis position, stored revolution counts and the controller's motion model instead of acting as a general-purpose I/O assembly.
During service, ABB 3HAC046277-001 is handled as one measurement chain comprising the enclosure, RMU101 board, 3HAC044075-001 battery and axis harnesses. Connector identity is retained during transfer, and the revolution counters are updated only after the replacement unit and physical robot axes have been reconciled.
02
Technical Information
Technical item
Specification
Brand
ABB
Model
3HAC046277-001
Product name
Serial Measurement Unit with RMU101 SMB
Country
Sweden / Switzerland
System role
Axis resolver measurement and revolution storage
Measurement board
RMU101 3HAC044168-001
Battery
Lithium battery pack 3HAC044075-001
Input path
Robot-axis resolver harnesses
Output path
Serial measurement data to robot controller
Stored record
Axis revolution counters
Service boundary
Complete measurement unit and identified harnesses
Commissioning
Update revolution counters after verified replacement
03
Monitoring and Control
ABB 3HAC046277-001 keeps the physical axes and the controller's position model connected through one battery-backed measurement path.
01
Resolver acquisition
Each resolver reports shaft angle to the RMU101 board. The board groups those signals into the serial position record consumed by the motion controller, so a disturbed connector can be distinguished from a mechanical axis movement.
02
Revolution tracking
The battery-backed memory preserves revolution counts while cabinet power is absent. Those counts give the controller the coarse multi-turn position that complements the resolver's position within one revolution.
03
Controller handoff
After power returns, the unit sends measured axis data to the robot controller. Motion is accepted only when the stored counts, resolver signals and configured mechanical-unit record describe the same physical axes.
04
Diagnostics and Protection
Service checks on ABB 3HAC046277-001 separate battery, connector and calibration conditions before robot motion is enabled.
01
Battery-state check
A battery warning is treated as a storage-path issue rather than an immediate resolver failure. Replace the battery under the specified procedure so the stored revolution relationship is not lost unnecessarily.
02
Harness verification
Inspect every resolver and controller connector for its original position, locking feature and cable support. A crossed axis connector can produce coherent electrical data for the wrong mechanical axis.
03
Post-service validation
After replacement, update the revolution counters at the robot's known calibration positions and compare displayed axis values with the physical marks before permitting automatic operation.
05
Frequently Asked Questions
How should a technician preserve axis position after a battery warning for ABB 3HAC046277-001?
For ABB 3HAC046277-001, check the battery record and replace it under controlled power conditions before updating any revolution counter.
What should be checked when a team needs to avoid mixing resolver connectors during replacement for ABB 3HAC046277-001?
For ABB 3HAC046277-001, label every connector by axis and reconnect it to the same RMU101 position before power-up.
Why might a site need to recover from lost revolution data for ABB 3HAC046277-001?
For ABB 3HAC046277-001, place the robot at its calibration references and update only the affected counters after the resolver path is verified.
Which checks help a customer separate an SMB problem from a motor problem for ABB 3HAC046277-001?
For ABB 3HAC046277-001, compare several stationary axis readings and inspect the common serial-measurement path before disturbing the motor.
What is the safest way to verify a replacement before automatic motion for ABB 3HAC046277-001?
For ABB 3HAC046277-001, confirm connector locking, battery status, calibration marks and displayed axis values in manual mode.
How can commissioning staff retain the correct service record for ABB 3HAC046277-001?
For ABB 3HAC046277-001, keep the complete 3HAC046277-001 unit identity with its RMU101 board, battery and robot serial information.
Moore Automation keeps robot measurement-unit identifiers, supporting photographs and destination details associated with the same enquiry so a battery, board or complete unit request is not confused.
Measurement recordsBoard and unit references remain linked
Robot contextAxis and controller family retained
Enquiry continuityQuantity and destination stay together
Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.


No related record found