High-ratio conversion
The 236.36 reduction turns relatively fast motor rotation into the slower output required at axis 6. That relationship allows the wrist to develop torque without treating motor speed as joint speed.
Welcome to Moore Automation Limited

|
Copy and share this link on social network or send it to your friends
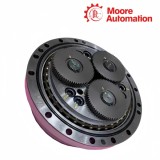
Copy| Product Name | ABB RV-500N-236.36 3HAC048293-001 Axis-6 Reduction Gear |
| Item NO. | 2930451 |
| Weight | 0.1 kg = 0.2205 lb = 3.5274 oz |
| Category | ABB |
| Brand | ABB |
| Creation Time | 2026-11-06 |
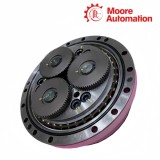
ABB RV-500N-236.36 3HAC048293-001 is the axis-6 reduction gear installed at the end of the upper arm on the ABB IRB 8700 robot. Its 236.36 reduction converts motor-and-pinion input into the slower, higher-torque rotation required by the robot's terminal wrist axis.
Inside the wrist drive, ABB RV-500N-236.36 3HAC048293-001 receives rotation through the axis-6 pinion and carries the reduced output to the wrist interface. Gear mounting, lubrication, sealing and the connected motor-feedback path work together; changing only one of those relationships can affect backlash, position accuracy or load transfer.
Replacement of ABB RV-500N-236.36 3HAC048293-001 requires support of the wrist and attached load, isolation of drive energy and protection of open mechanical interfaces. The gear is seated without using fasteners to pull misaligned parts together, then the axis is calibrated and tested at controlled speed.

| Technical item | Specification |
|---|---|
| Brand | ABB |
| Model | RV-500N-236.36 3HAC048293-001 |
| Product name | Axis-6 reduction gear |
| Country | Sweden / Switzerland |
| Robot family | ABB IRB 8700 |
| Axis assignment | Axis 6 |
| Gear designation | RV-500N-236.36 |
| Reduction ratio | 236.36 |
| Installed position | End of upper arm, L2 wrist position |
| Finish | ABB Orange |
| Input relationship | Axis-6 motor and pinion |
| Output relationship | Reduced wrist rotation and torque |
ABB RV-500N-236.36 3HAC048293-001 shapes the speed, torque and positional behavior of the IRB 8700 terminal wrist axis through one high-ratio mechanical path.
The 236.36 reduction turns relatively fast motor rotation into the slower output required at axis 6. That relationship allows the wrist to develop torque without treating motor speed as joint speed.
The pinion, reduction stages and output interface carry reversing loads through the wrist structure. Mounting faces and fastener sequence therefore influence how evenly those loads enter the gear.
Resolver data is measured at the motor side while the robot model interprets the geared joint position. Backlash or disturbed mounting can therefore appear as a mechanical response issue even when feedback remains electrically stable.
Install ABB RV-500N-236.36 3HAC048293-001 with the wrist supported and every sealing, lubrication and calibration step tied to the same axis-6 service record.
Remove payload influence, position and support the wrist, isolate energy and secure the axis before separating the motor, covers or upper-arm interface.
Protect open surfaces, transfer required seals and lubrication, align the gear to its locating features and tighten in sequence without using bolts to overcome misalignment.
Reconnect the motor and feedback chain, restore covers, calibrate axis 6 and run limited motion while checking sound, current, direction and repeatable return to reference.
For ABB RV-500N-236.36 3HAC048293-001, match RV-500N-236.36 3HAC048293-001 to the IRB 8700 serial and axis-6 spare-parts record.
For ABB RV-500N-236.36 3HAC048293-001, remove payload effects and mechanically secure the upper-arm and wrist structure before disturbing the gear.
For ABB RV-500N-236.36 3HAC048293-001, keep dirt and impact away from mounting faces, seals and lubricant while 3HAC048293-001 is out of the robot.
For ABB RV-500N-236.36 3HAC048293-001, align locating features and hand-seat the gear rather than drawing a misaligned unit into place with fasteners.
For ABB RV-500N-236.36 3HAC048293-001, check mounting, pinion engagement and gear seating before changing controller parameters.
For ABB RV-500N-236.36 3HAC048293-001, calibrate RV-500N-236.36 3HAC048293-001 and verify low-speed motion under a controlled load condition.
Moore Automation keeps the complete RV designation, 3HAC order number, robot family and axis position together, reducing confusion between visually similar wrist gears.


Moore Automation Sales Team
Copyright © 2004–2026 www.mvme.cn. All rights reserved.
Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.
No related record found