Welcome to Moore Automation Limited

0
Loadding...
 

sales@mvme.cn    Phone: +86 18030175807

Home>ABB>ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear
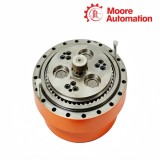
ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear

ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear Item NO.: 2930111

Write a Review
US$ 1.00
Quantity
Stock ( 28 )

Copy and share this link on social network or send it to your friends

Copy
Request Price & AvailabilitySend the part number and quantity. Our team will confirm stock, condition, lead time and the best quotation.
  • MOQ: 1 piece
  • International shipping
  • 1-year warranty on eligible items
  • Fast response during business hours
Product Name ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear
Item NO. 2930111
Weight 0.1 kg = 0.2205 lb = 3.5274 oz
Category ABB
Brand ABB
Creation Time 2026-11-05

ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear | Moore Automation
ABB ROBOTICSRV700F-269.21ROBOT SERVICE PART
ABB IRB 7600 heavy-payload robot drive
ABB RV700F-269.21 3HAC031580-001 IRB 7600 Axis-3 Reduction Gear

IRB 7600 Axis-3 Reduction Gear documented for ABB IRB 7600 heavy-payload robot drive.

01

Product Description

ABB RV700F-269.21 3HAC031580-001 is the axis-3 reduction gear used in documented ABB IRB 7600 manipulator configurations. Located between the third-axis servo motor and arm structure, the RV700F reduction stage converts the motor's high-speed input into the lower-speed, high-torque movement needed to position the heavy upper arm.

The mechanical chain of ABB RV700F-269.21 3HAC031580-001 begins at the motor pinion, passes through the 269.21 reduction and ends at the axis-3 output structure. Controller feedback is measured at the drive side, so correct mounting, gear condition and calibration are required for commanded motor position to correspond to actual arm motion.

Service on ABB RV700F-269.21 3HAC031580-001 requires the heavy axis to be placed in the specified service position and positively supported before the drive train is opened. After mating-face preparation and sealed assembly, lubrication, leakage, backlash, calibration and slow axis-3 movement are checked before production operation.

02

Technical Data

Technical item Specification
Brand ABB
Model RV700F-269.21 3HAC031580-001
Product name IRB 7600 axis-3 reduction gear
Country Switzerland / Sweden
Robot family IRB 7600
Installed axis Axis 3
Gear type RV700F
Reduction ratio 269.21
Input interface Axis-3 motor pinion
Output interface Heavy upper-arm structure
Service condition Axis placed and positively supported
Post-install checks Lubrication, leakage, backlash and calibration
Ordering identity Complete suffix -001 required
03

Typical Applications

ABB RV700F-269.21 3HAC031580-001 is applied in the IRB 7600 third-axis drive where a high-speed servo motor must position the heavy upper-arm structure through a fixed mechanical reduction. Its application is defined by that installed robot, axis and ratio rather than by a broad claim of general gearbox use.

01

Heavy-payload arm positioning

Within the IRB 7600, the reduction stage provides the torque relationship needed to raise, lower and hold the connected upper-arm structure under controller command. The gear works with the installed motor, brake and feedback chain so controlled motor input becomes stable movement of the gravity-influenced arm.

02

Axis-3 speed conversion

Motor rotation enters through the axis-3 pinion and is reduced by the 269.21 mechanical relationship before reaching the arm-side output. This converts high motor speed into controlled angular travel, while feedback and calibration let the controller associate drive-side movement with actual arm position.

03

Service restoration

When the installed reduction stage is replaced, the complete ABB RV700F-269.21 3HAC031580-001 record restores the documented ratio, locating geometry and mounting interface. The application remains the IRB 7600 axis-3 path; the order identity prevents another RV700F execution from being accepted only by family name.

04

Installation Highlights

The IRB 7600 upper arm is positively restrained before ABB RV700F-269.21 3HAC031580-001 is touched, and final acceptance combines mechanical, sealing and controller checks. The sequence prevents the heavy structure from moving while the load path is open and avoids using servo torque to correct an alignment problem.

01

Place and support the arm

Move the robot to the documented service position, isolate and verify drive power, and place rated support under the heavy upper structure. Confirm that axis 3 cannot rotate before releasing the motor, brake or gear interface; the support remains until brake holding and controlled travel have been verified.

02

Prepare and mount

Inspect the motor pinion, locating faces, seals and fasteners, clean the interfaces and seat ABB RV700F-269.21 3HAC031580-001 without impact or side load. Allow the locating geometry to establish alignment, tighten in the documented sequence and restore the specified lubrication and covers.

03

Calibrate and observe

Check sealing, free movement and backlash before drive enable, then update or verify the axis calibration record. Begin with short low-speed travel while observing sound, direction, following behavior and load response; stop on leakage, binding or unexpected deviation before production speed.

05

Product Q&A

Why must the complete ABB RV700F-269.21 3HAC031580-001 record be checked instead of using RV700F alone?

ABB RV700F-269.21 3HAC031580-001 combines the gear family, 269.21 reduction and exact order number; omitting those fields can select a gear with the wrong ratio or installed interface for the IRB 7600 axis-3 drive.

How is the installation position of ABB RV700F-269.21 3HAC031580-001 verified before lifting the gear?

Verify ABB RV700F-269.21 3HAC031580-001 against the IRB 7600 axis-3 service record, identify the motor and arm-side interfaces, and place the heavy upper arm in the specified supported service position before lifting begins.

Why does ABB RV700F-269.21 3HAC031580-001 require positive arm support?

ABB RV700F-269.21 3HAC031580-001 sits in a heavy, gravity-influenced drive path; positive support prevents uncontrolled movement when the gear is disconnected.

What interfaces should be inspected with ABB RV700F-269.21 3HAC031580-001?

Inspect the motor pinion, locating faces, seals, fasteners and output-side mounting structure when servicing ABB RV700F-269.21 3HAC031580-001.

What indicates that ABB RV700F-269.21 3HAC031580-001 should not continue its test?

Stop testing ABB RV700F-269.21 3HAC031580-001 if leakage, binding, abnormal sound, excessive backlash or unexpected following error appears.

Why can ABB RV700F-269.21 3HAC031580-001 pass a stationary check but show following error in motion?

A stationary check does not load the complete torque path of ABB RV700F-269.21 3HAC031580-001. Following error during controlled motion requires the 269.21 gear interface, backlash, lubrication, calibration and connected motor path to be checked before production speed is restored.

06

Brand Supply Scope

Moore Automation

https://www.mvme.cn

Moore Automation covers industrial robot and automation references from ABB alongside Siemens, Rockwell Automation, Honeywell, Schneider Electric and other manufacturers. Product type, full identifier, quantity and destination remain linked for review.

Robot partsDrive, motor and cable records
AutomationPLC, I/O and communication
MonitoringMachinery and process hardware
07

Recommended Products

YokogawaALR121-S50
ABB3HAC034647-003
B&R5AP1120.0573-000
Bently Nevada330101-00-20-90-02-05
Bosch RexrothHCS01.1E-W0028-A-03-B-ET-EC-NN-L3-NN-FW
FoxboroFBM241D
GEIC5002TBW0000
HoneywellCC-TDOB11
MotorolaMVME172-263
ProSoftPLX31-PND-MBS
Rockwell Automation1756-L74
Schneider ElectricBMXAMO0210
YokogawaALR121-S51
ABB3HAC037635-001
B&RX20BM11
Bently Nevada330101-00-30-10-02-00
Bosch RexrothHCS01.1E-W0028-A-03-E-S3-EC-NN-L3-NN-FW
FoxboroFBM242
GEIC5005CAC0000
HoneywellCC-GAIX11
MotorolaMVME2604-761
Rockwell Automation1756-IB16
Schneider ElectricBMEP582040
YokogawaAAR145-S00 S1
ABB3HAC031580-001
B&R5AP1120.101E-000
Bently NevadaDS3800NDAD1H1C
GEIC5005CAC0001
MotorolaIC630MDL311
Rockwell Automation1756-L75
Schneider ElectricBMXP342020
YokogawaADV151-P00 S2
ABBIS200EGPAG1B
B&RX20BM12
Bently NevadaIC3600SNCF1
GEIC5005TAW0000
MotorolaIC200CPU001
Rockwell Automation1756-IB16D
Schneider ElectricTM241CE40R
YokogawaAAI141-S00 S2
ABB3HAC044504-001
B&R5AP1130.101E-000
Bently Nevada330180-90-05
GEIC5005TAW1000
Motorola2097-V33PR5-LM
Rockwell Automation1756-L82E
YokogawaASD143-P00 S1
ABB3HAC050308-003
B&RX20BM15
Bently Nevada3500/42M 176449-02
GEIC5005TAW4000
Rockwell Automation1756-OB16I
ABBPM5630-2ETH 1SAP131000R0378
B&R5AP1130.156B-000
Bently Nevada3300/16-13-01-00-00-00-00
GEIC5005TBW0000
Rockwell Automation1756-OB32E
ABBDI831 3BSE013212R1
B&RX20BM21
Bently Nevada3701/40 177896-05
08

Enquiry Information

Discuss the exact robot-part record
ManagerLeonia

No related record found

You May Also Like

Copyright © 2004–2026 www.mvme.cn. All rights reserved.

Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.