Welcome to Moore Automation Limited

0
Loadding...
 

sales@mvme.cn    Phone: +86 18030175807

Home>ABB>ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear
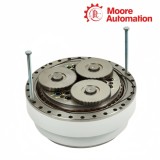
ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear

ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear Item NO.: 2930425

Write a Review
US$ 1.00
Quantity
Stock ( 28 )

Copy and share this link on social network or send it to your friends

Copy
Request Price & AvailabilitySend the part number and quantity. Our team will confirm stock, condition, lead time and the best quotation.
  • MOQ: 1 piece
  • International shipping
  • 1-year warranty on eligible items
  • Fast response during business hours
Product Name ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear
Item NO. 2930425
Weight 0.1 kg = 0.2205 lb = 3.5274 oz
Category ABB
Brand ABB
Creation Time 2026-11-06

ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear
ABBIRB 6700 Technical Product Record
RV-550N-252.33reduction gear
ABB Robotics · IRB 6700

ABB RV-550N-252.33 3HAC043072-003 IRB 6700 Axis Reduction Gear

IRB 6700 Axis Reduction Gear for the IRB 6700 system.

Complete articleRV-550N-252.33 3HAC043072-003
01

Product Summary

ABB RV-550N-252.33 3HAC043072-003 is a robot reduction gear used in the IRB 6700 drivetrain. The RV-550N mechanism reduces motor speed and transfers controlled torque to the assigned joint through the specified 252.33 ratio execution.

The motor coupling, gearbox housing, arm interface, seals and lubricant boundary operate together around ABB RV-550N-252.33 3HAC043072-003. Correct seating keeps the gear axis aligned while the output flange carries robot load without forcing the motor shaft or mounting faces.

Replacement of ABB RV-550N-252.33 3HAC043072-003 starts with mechanical support and stored-load control. After assembly, the joint is calibrated and moved at low speed to check direction, noise, backlash, sealing and temperature before normal acceleration.

02

Technical Details

Technical item
Specification
Brand
ABB
Model
RV-550N-252.33 3HAC043072-003
Product Name
IRB 6700 axis reduction gear
Country
Sweden
Gear Family
RV-550N
Robot Family
IRB 6700
Reduction Ratio
252.33
Mechanical Role
Motor-speed reduction and joint-torque transfer
Input Interface
Robot axis motor and pinion
Output Interface
Joint arm / output flange
Service Boundary
Housing, seals and lubricant
Installation Requirement
Support axis before release
Post-Installation
Calibration and low-speed motion check
03

Performance Characteristics

Performance Characteristics

ABB RV-550N-252.33 3HAC043072-003 converts motor rotation into high joint torque; stable performance depends on gear engagement, lubricant condition, alignment and calibrated joint position.

01

Transfer torque cleanly

Aligned input and output interfaces prevent side load while the 252.33 gear execution carries the intended robot joint load.

02

Control backlash and noise

Slow reversals reveal abnormal clearance, tooth damage or mounting error before higher speed loads the restored drivetrain.

03

Protect the lubricant boundary

Clean sealing surfaces and the specified lubricant condition reduce leakage, heat and wear around the RV-550N housing.

04

Installation Highlights

Installation Highlights

ABB RV-550N-252.33 3HAC043072-003 must be removed and installed with the joint load supported; its mass and coupling geometry are part of the service sequence.

Unload the joint

Move to the prescribed service pose, secure the arm and release mechanical load from the gearbox interface.

Keep faces aligned

Clean the motor, housing and output mating surfaces; guide the unit into position without using bolts to pull a misaligned assembly together.

Calibrate before duty

Restore seals and lubricant, perform the robot calibration procedure and compare low-speed direction, noise and current before production.

05

Customer Questions

Q01How do I avoid ordering the wrong ratio when replacing ABB RV-550N-252.33 3HAC043072-003?+
Use the complete ABB RV-550N-252.33 3HAC043072-003 record and robot serial, not RV-550N alone; the 252.33 execution and installed joint assignment must agree before the arm is dismantled.
Q02Why must the robot arm be supported before ABB RV-550N-252.33 3HAC043072-003 is released?+
ABB RV-550N-252.33 3HAC043072-003 sits in the torque path, so removing its fasteners without external support can let stored gravity load rotate the joint and damage mating faces or injure personnel.
Q03What does a tight spot after fitting ABB RV-550N-252.33 3HAC043072-003 usually indicate?+
Stop motion and inspect ABB RV-550N-252.33 3HAC043072-003 input coupling, output alignment and mounting-face seating; bolts must not be used to pull a misaligned gearbox into position.
Q04How should leakage around ABB RV-550N-252.33 3HAC043072-003 be investigated?+
Clean the ABB RV-550N-252.33 3HAC043072-003 housing, identify the exact seal boundary, verify the specified lubricant state, and observe repeated low-speed travel before deciding the source.
Q05Why is calibration required after ABB RV-550N-252.33 3HAC043072-003 replacement?+
Replacing ABB RV-550N-252.33 3HAC043072-003 changes the serviced mechanical path; calibration restores agreement between controller position, joint angle and the rebuilt torque chain.
Q06Which evidence helps assess abnormal noise from ABB RV-550N-252.33 3HAC043072-003?+
Provide ABB RV-550N-252.33 3HAC043072-003, axis and pose, load condition, direction, speed, current trend, temperature and a recording showing whether the noise repeats at the same angle.
06

Our Services

Moore Automation

https://www.mvme.cn

Moore Automation coordinates product-reference checking, available-document review, packing information and enquiry communication for industrial automation parts. The service route keeps the requested article, quantity and destination together without implying manufacturer authorization or guaranteed availability.

Reference reviewBrand, model and order number are checked as one article record.
File coordinationAvailable manuals and supporting records remain attached to the request.
Packing detailsProduct form and destination guide the packing information retained.
Direct enquiryTechnical and commercial questions follow one coordinated communication route.
07

Related Products

GEDS200NATOG3A
MotorolaMVME162-512A1
Allen-Bradley2093-AC05-MP1
Rockwell Automation1756-L83EP
GEDS200SVIAG1A
GEIC200ALG620
GEDS200SPCBG1A
GEIC630MDL304
ABB RoboticsKSP600-3X64
GEIS200EDFFH3A
ABB Robotics3HAC043090-00
GEIS200TREGH1B
YokogawaANR10D
GEHE800HSC601
GEIC200ALG322
GEIS200TTURH1B
GEIS210DTAIH1A
GEIS200BICLH1B
Rockwell Automation5069-L310ERS2
GEDS200EXPSG1A
GEIS215UCVEM06A
MotorolaMVME61006E-0163
MotorolaMVME2604-761-IO
GEIC630MDL375
GEIS200ESELH3A
MotorolaMVME2304-0143
GEIC200MDL744
GEIS200EXHSG4A
GEIC200ALG321
TriconexTRICON 3723X
GEIS220PTURH1B
Rockwell Automation1783-ETAP1T2SFP
Bently Nevada60M500-05-00
ABBPM5650-2ETH-XC
Rockwell Automation2711P-T15C21D8S
GEIS200ESYSH1A
GEIC630CCM390
GEIS200EACFG3A
Rockwell Drives81007-465-51-R
GE Excitation4136J57-G01
YokogawaANB10D-425-CU2N
Rockwell Automation2711P-T15C22D8S
ABB RoboticsDSQC1024A
MotorolaMVME162-723
GEIC630MDL367
GEIC630MDL357
ABB RoboticsKSP600-3X40
ABB RoboticsKSP600-3X40UL
GEIS200EGDMH1A
MotorolaMVME147-010A
GEDS200SHVMG1A
MotorolaMVME2304-0121
GEIS200EGPAG1A
MotorolaMVME6100-0171
GEDS200TCEBG1B
MotorolaMVME162PA-252SE
Rockwell Automation2711P-T19C22D9P
Rockwell Drives80190-320-02-R
TriconexTRICON 4701X
ABB Robotics3HAC055688-004
08

Enquiry Details

Moore Automation
ManagerLeonia

No related record found

Copyright © 2004–2026 www.mvme.cn. All rights reserved.

Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.