Position-dependent force
The device's geometry changes as the upper arm moves. That force relationship assists the axis drive without replacing the motor, brake or controller's position regulation.
Welcome to Moore Automation Limited

|
Copy and share this link on social network or send it to your friends
Copy| Product Name | ABB 3HAC043477-002 Balancing Device |
| Item NO. | 2930461 |
| Weight | 0.1 kg = 0.2205 lb = 3.5274 oz |
| Category | ABB |
| Brand | ABB |
| Creation Time | 2026-11-06 |
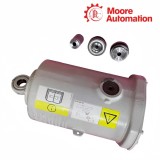
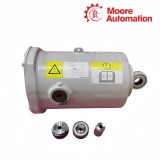
ABB 3HAC043477-002 is the Graphite White balancing device used on applicable ABB IRB 6700 manipulators. It counterbalances the upper-arm load so the axis drive works against a controlled spring or gas-force relationship instead of carrying the entire gravitational moment alone.
Mounted between the robot structure and the moving arm, ABB 3HAC043477-002 changes force as the arm travels through its range. Its attachment points, pressure or spring condition and mechanical alignment work with the axis motor and gearbox; the device does not issue an electrical control signal.
Service on ABB 3HAC043477-002 starts with positioning and supporting the robot so stored mechanical energy is controlled. The exact IRB 6700 reach and payload execution is confirmed, attachment hardware is transferred in the documented sequence, and the arm is moved slowly to verify clearance and balanced behavior.
| Technical item | Specification |
|---|---|
| Brand | ABB |
| Model | 3HAC043477-002 |
| Product name | Balancing device |
| Country | Sweden / Switzerland |
| Robot family | ABB IRB 6700 |
| Primary function | Counterbalance upper-arm gravitational load |
| Finish | Graphite White |
| Energy type | Stored mechanical balancing force |
| Installed relationship | Robot structure to moving upper arm |
| Selection basis | Robot reach and payload execution |
| Safety boundary | Support arm and control stored energy before removal |
| Commissioning | Slow-range clearance and balance verification |
ABB 3HAC043477-002 changes its balancing force with arm position so the robot drive sees a moderated gravitational load throughout the working range.
The device's geometry changes as the upper arm moves. That force relationship assists the axis drive without replacing the motor, brake or controller's position regulation.
Balancing force remains present even when electrical power is removed. The arm and device must therefore be supported and released only through the documented mechanical sequence.
A healthy balance device reduces the gravitational component seen by the axis drive. Binding, incorrect attachment or lost force can appear as uneven current or motion across the arm range.
Install ABB 3HAC043477-002 by controlling the arm position, stored energy and exact attachment geometry from removal through functional verification.
Move to the specified service position, remove payload influence where required, isolate energy and mechanically support the upper arm before loosening either attachment.
Use the prescribed lifting and release points, keep body and tools outside the force line, and fit the replacement to the correct IRB 6700 mounting locations without forcing the joints.
Restore guards and hardware, then move the arm slowly through the permitted range while checking clearance, balance behavior, drive current and absence of binding.
For ABB 3HAC043477-002, match 3HAC043477-002 to the IRB 6700 reach, payload and manipulator serial record.
For ABB 3HAC043477-002, support the upper arm and follow the documented release geometry even after electrical isolation.
For ABB 3HAC043477-002, compare current across the arm range and inspect balance-device attachment and movement before replacing the drive.
For ABB 3HAC043477-002, reposition the supported arm until both 3HAC043477-002 attachments align naturally.
For ABB 3HAC043477-002, move the arm slowly and observe the device, covers, hoses and nearby structure through the permitted range.
For ABB 3HAC043477-002, check attachment hardware, balanced behavior and controlled robot motion before restoring payload operation.
Moore Automation can retain older robot-part numbers, visible revisions, photographs and destination details in one enquiry without presenting availability as guaranteed.


Moore Automation Sales Team
Copyright © 2004–2026 www.mvme.cn. All rights reserved.
Disclaimer: Moore Automation Limited is an independent reseller and is not an authorized distributor or representative of the manufacturers featured on this website. Product names and trademarks belong to their respective owners.
No related record found